Truth before color
Running, degraded, stopped, and unreachable are derived from current probes—not configuration or process existence.
Open-source robot fleet control
Bring any robot. Add your stack. Govern them as one fleet.
RoboStew is short for Robot Steward.
RoboStew turns live telemetry, workload heartbeats, and functional probes into one honest fleet view—without pretending that configured means running.

Current probes, not static green claims.
The local edition
A deterministic scenario moves five simulated robots from nominal operation through attention and bounded recovery, then back to stable state. Every status links to current evidence.
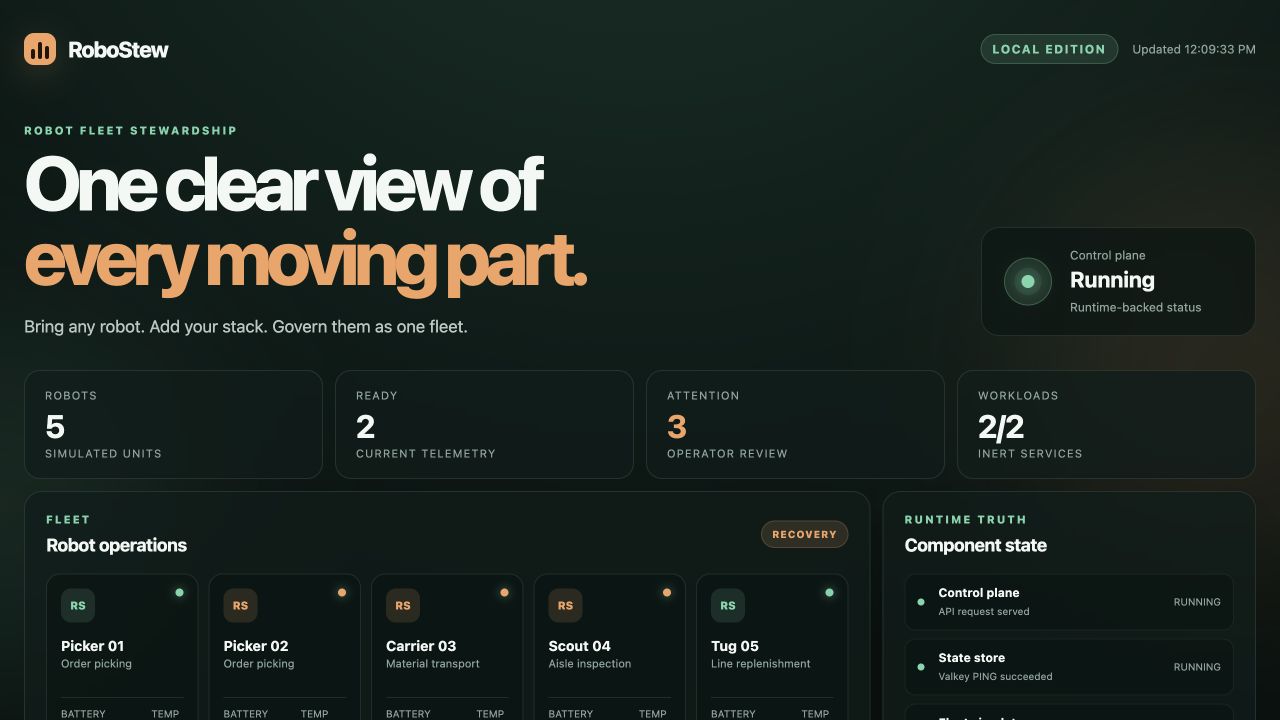
Running, degraded, stopped, and unreachable are derived from current probes—not configuration or process existence.
Robot condition, telemetry freshness, and inert workload heartbeats reconcile into one operator view.
The local edition has no cloud credentials, deployment authority, host mounts, or robot-actuation path.
Five-minute path
Bring Git and Docker Desktop on an Apple Silicon Mac. RoboStew builds the local control plane, starts five services, waits for functional health, and prints one loopback URL.
$ git clone https://github.com/
  robostew-project/robostew.git
$ cd robostew
$ ./robostew start
$ ./robostew demoBeyond the laptop
The public reference code preserves the useful engineering patterns from a privately validated Azure, Dell Ubuntu, and LF Edge EVE deployment—without publishing private infrastructure.
Runtime truth, server-side sanitization, EVE inventory reconciliation, bounded AI requests, negative policy tests, and authenticated telemetry are included as tested source. Full Azure/Dell reconstruction is a possible v0.2.0—not a v0.1.0 claim.
Inspect reference codeHonest scope
Five simulated robots, two inert workloads, durable local state, runtime probes, and a deterministic recovery demonstration.
Tested, sanitized patterns from a private deployment—clearly separated from the five-minute local edition.
No motor, actuator, ROS 2 navigation stack, emergency stop, autonomous remediation, or production certification.
Open by default
Use the local core. Inspect the boundaries. Replace the simulator with your adapters. Contribute platform validation without inheriting someone else’s private infrastructure.